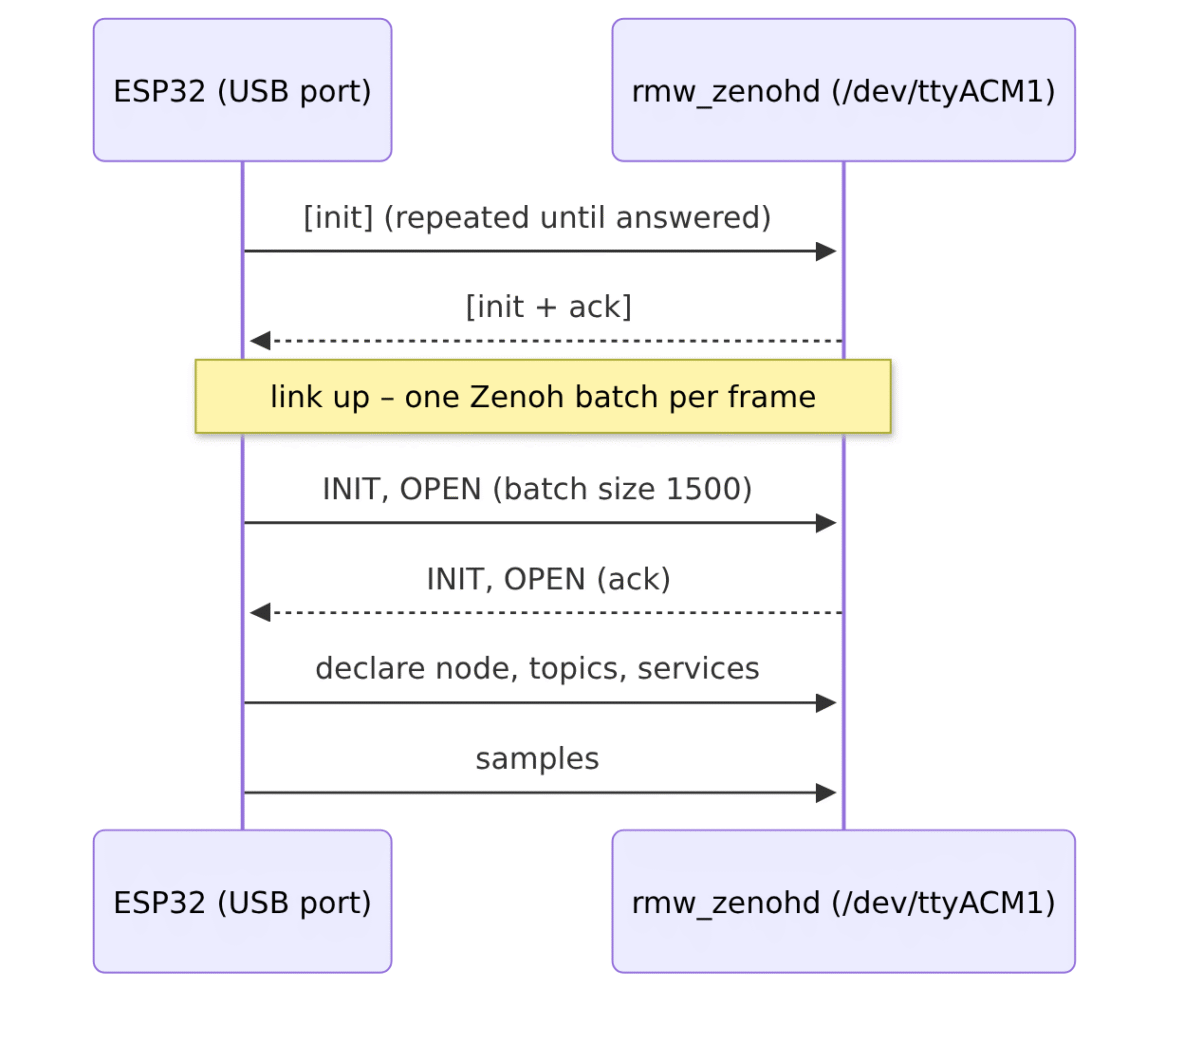
If you want to add sensors to a system using ROS 2 then this is a super-quick and easy win. The same agent-free ESP32 ROS 2 node, now over the USB cable that was plugged in anyway – to the stock Zenoh router, switchable at run time, with the console still there when you want it.
Agent-free ROS 2 on an ESP32

Plug an I2C sensor into an ESP32 and watch it appear as a typed ROS 2 topic – over Zenoh, with no micro-ROS agent in sight.